 Ongoing
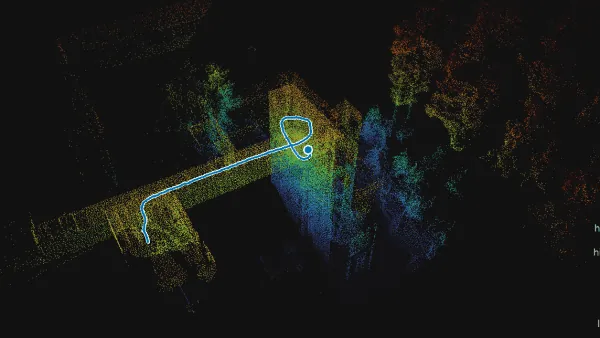
AGIptive-LIOM: Failure-Aware LiDAR-Inertial Odometry for Quadrotors (Tentative)
LiDAR-inertial odometry for quadrotors that fails rarely and visibly, and tells the flight controller when it is degraded.
 Sasa
I'm a doctoral researcher and Marie Skłodowska-Curie fellow in the Computer Vision Group at Tampere University, Finland, within the EU RAICAM doctoral network. I design and prototype agile aerial robots and aerial manipulators, build their digital twins, and develop robust, learning-based state estimation that runs on the edge.
Now
Doctoral Researcher, Tampere University
MSCA RAICAM network · since 2023
Previously
Aerial Robotics Research Facility
Kyungpook National University, Korea · MSc 2024
Recognition
IROS 2026 Earth Rover Challenge winner
ICRA 2025 runner-up · DNA+ 2022 Grand Prize · IMechE Project Award 2019
Research in progress. These pages update as results come in.
AGIptive-LIOM: Failure-Aware LiDAR-Inertial Odometry for Quadrotors
LiDAR-inertial odometry for quadrotors that fails rarely and visibly, and tells the flight controller when it is degraded.
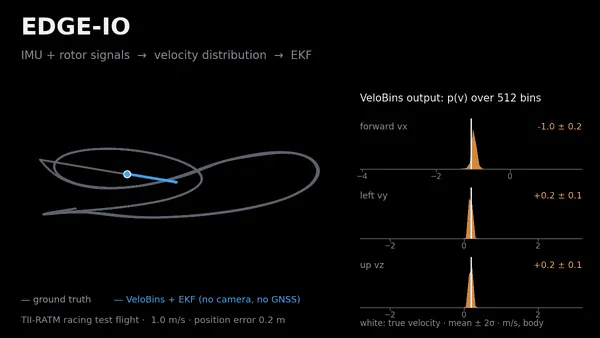 EDGE-IO: Calibrated Learned Inertial Odometry Across Quadrotor Platforms
Learned inertial odometry for quadrotors that predicts a calibrated velocity distribution from IMU and rotor signals, fuses it in an EKF, and is being extended to one ...
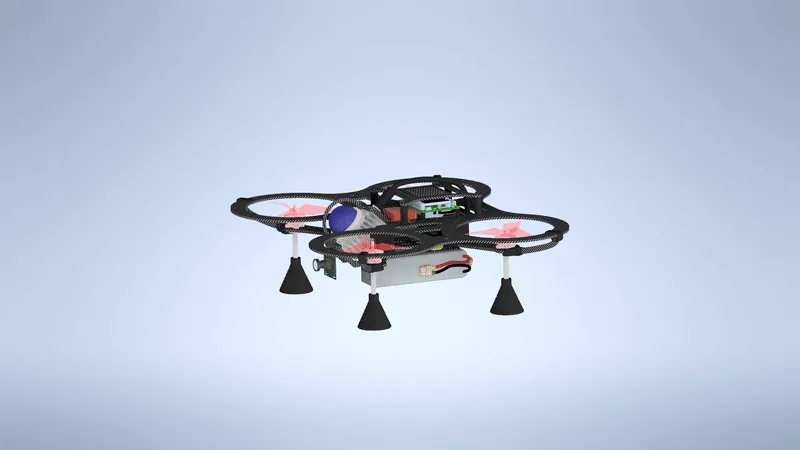 Agipix: An Open Source Aerial Agile Autonomy from Sim-to-Real
An open hardware and software platform for indoor aerial autonomy whose containerised ROS 2 stack runs unchanged in an Isaac Sim digital twin and on the real drone. Pu...
Ongoing
LiDAR-inertial odometry for quadrotors that fails rarely and visibly, and tells the flight controller when it is degraded.
Ongoing
Learned inertial odometry for quadrotors that predicts a calibrated velocity distribution from IMU and rotor signals, fuses it in an EKF, and is being extended to one encoder sh...
 🏆 1st place
Team ManseRobot from Tampere University won the Earth Rover Challenge at IROS 2026, finishing first overall out of 12 teams, ahead of NYU and Anna University, with one learned n...
Ongoing
An open hardware and software platform for indoor aerial autonomy whose containerised ROS 2 stack runs unchanged in an Isaac Sim digital twin and on the real drone. Published at...
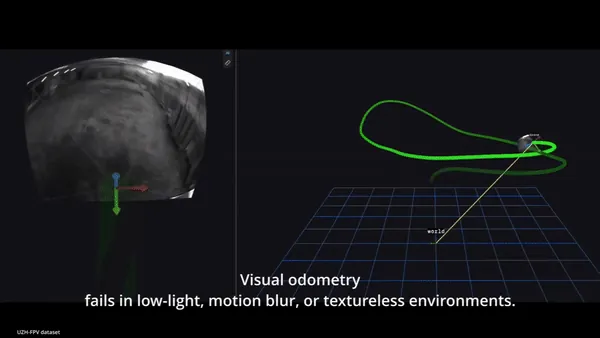
We propose a learning-based inertial odometry algorithm that integrates the full quadrotor dynamics, including body-frame torques, as model inputs. The proposed method outperfor...
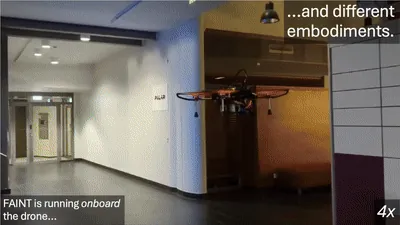
Simulator-trained visual navigation policies built on pretrained visual representations outperform their real-world-trained counterparts by 31% and the prior state of the art by...
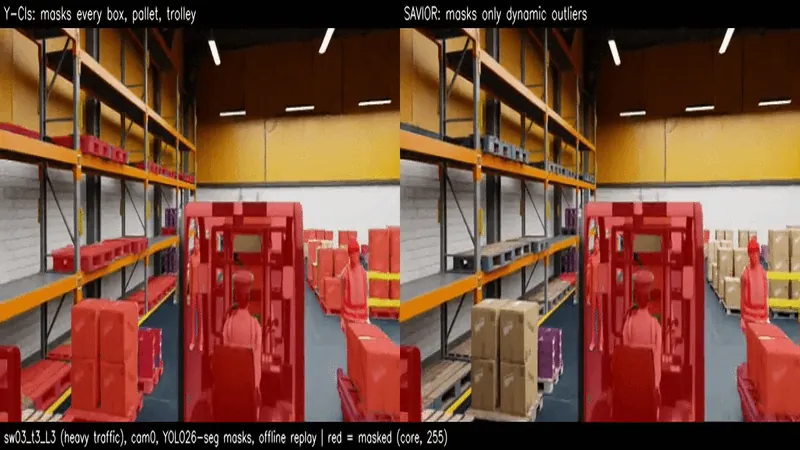
A semantic front end for visual-inertial odometry that masks only objects that actually move. In a controlled simulated-warehouse study it cut OpenVINS error by 48% in medium an...
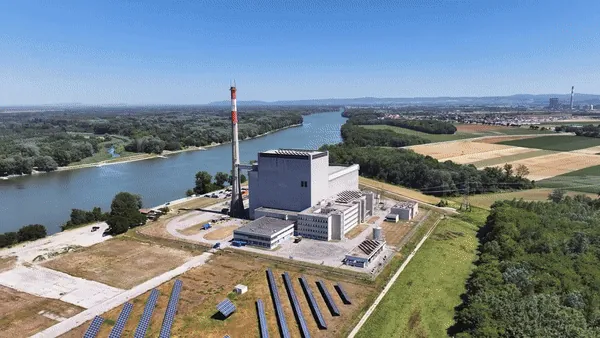
A low-cost drone and ground-robot inspection system built in three weeks for the EnRicH 2025 hackathon at the Zwentendorf nuclear power plant, published at IEEE SSRR 2025.
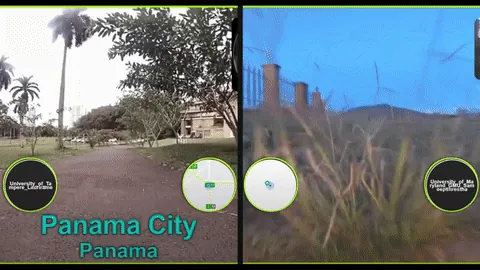
Co-developed a data driven model capable of in-the-wild navigation for mobile robots. The method is put to test at the ICRA 2025.
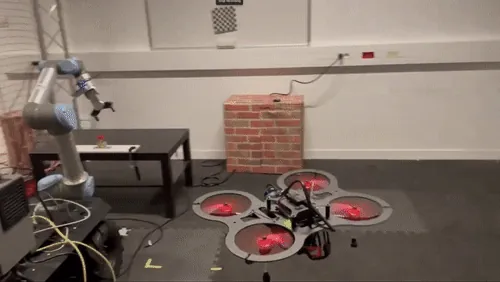
A ROS 2 real-time air–ground collaborative autonomy framework for industrial inspection, where a drone and a ground robot share a semantic map and tasks. Demonstrated at ENSTA P...
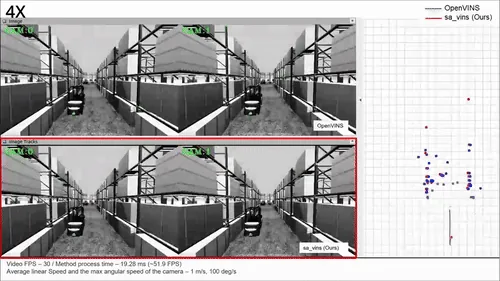
Developed a real-time semantic-aided Visual–Inertial Odometry (VIO) system for autonomous robots in dynamic indoor environments. Designed interaction-based dynamic object filter...
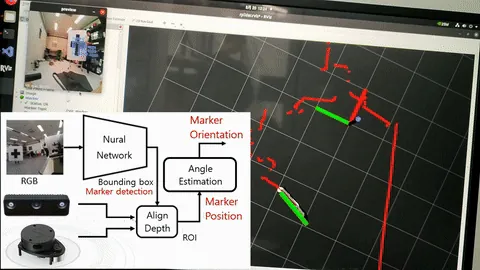
Entry to KUAM 2023 focused on autonomous last-mile delivery to apartment verandahs using a lightweight UAV platform. Key innovations included lidar + depth fusion for verandah d...
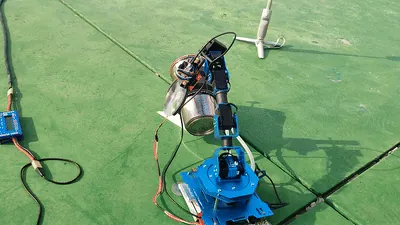
This project demonstrates an integrated solar water-heating prototype that combines a PMMA Fresnel lens with a 6-DOF robotic manipulator for precise solar tracking. The system u...
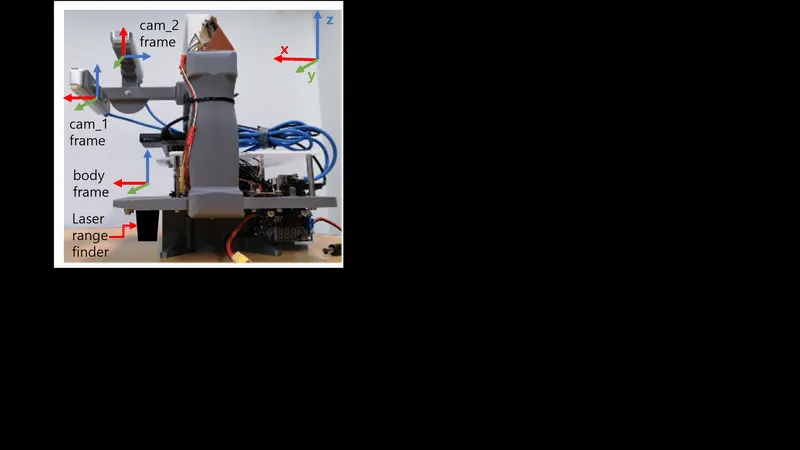
Developed a failure-aware visual–inertial navigation system that fuses multiple tracking cameras using an Interacting Multiple-Model (IMM) filter. Achieved real-time, robust pos...
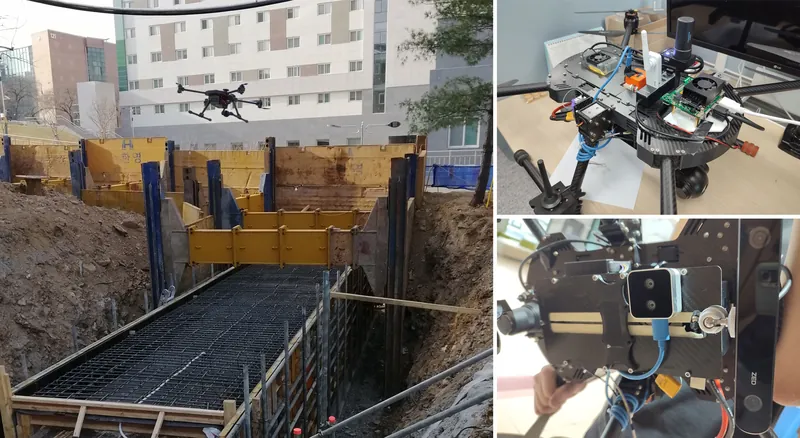
Development of an automated aerial inspection system for reinforced concrete components using drones equipped with depth sensors and machine learning. The system enables accurat...
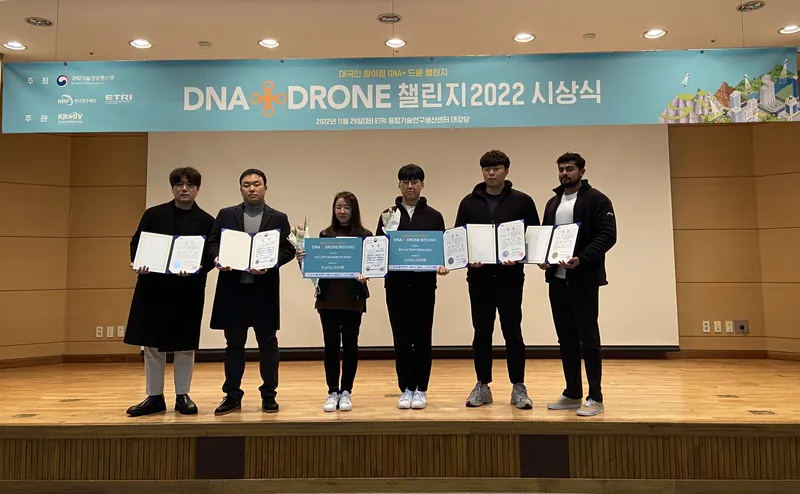
This competition is conducted by the Korean water resources agency (K-Water) and the ETRI research institute. The event consisted of 3 main events; a Business event, a river, an...
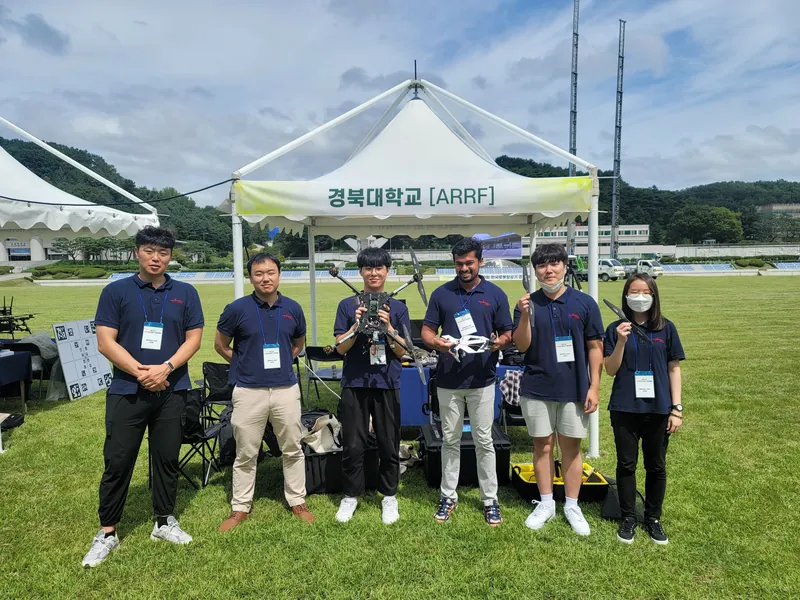
Famously known as Korea's most prestigious UAV contest, the '20th Korea Robot Aircraft Contest KUAM 2022 was held on the 20th of September. As a part of the ARRF (Aerial Robotic...
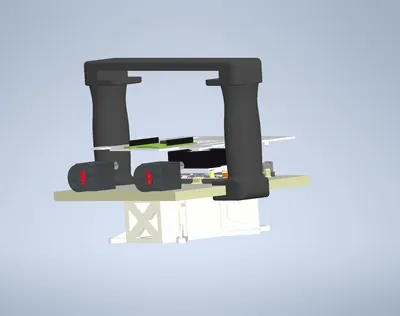
This project presents a synchronized visual-inertial sensor system using the Jetson Orin platform for accurate real-time SLAM.
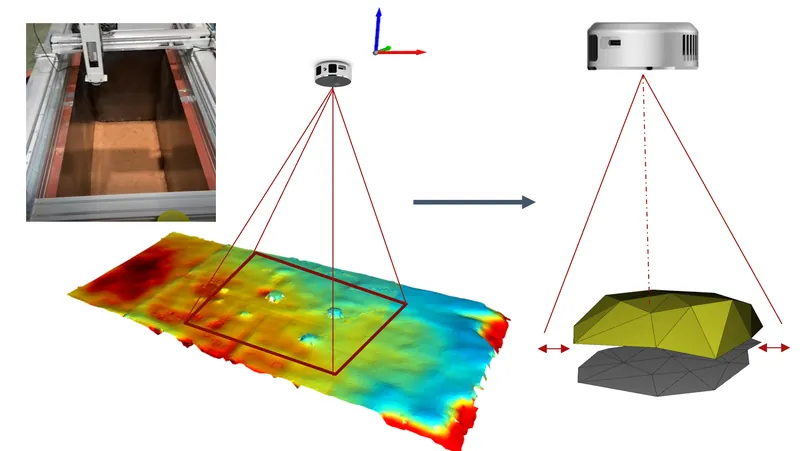
This project addresses the construction industry's shift toward automation by introducing a computer vision-based method for detecting and quantifying uneven material layers us...
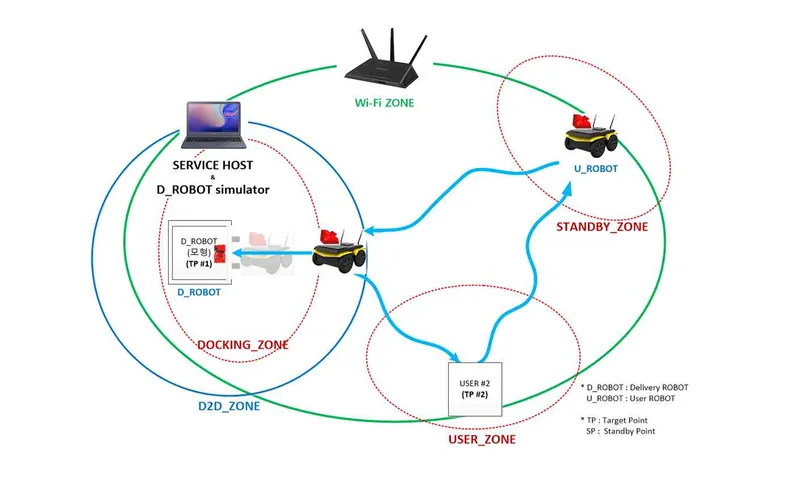
This project focused on developing a docking platform for unmanned robots using BLE 5.1 wireless communication and SLAM-based navigation. The system integrated lidar-based mappi...
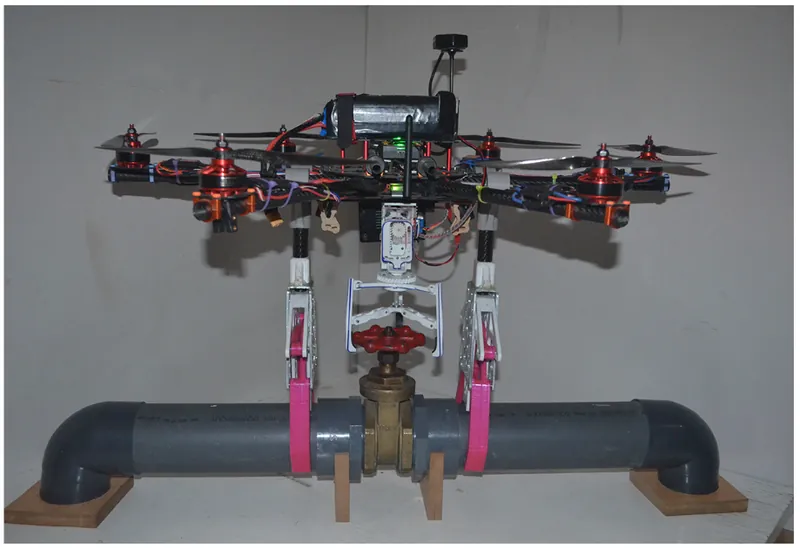
In my final year of undergraduate research, the aim was to Design and develop an unmanned manipulator to execute an operation which is unreachable to humans due to a hazardous e...
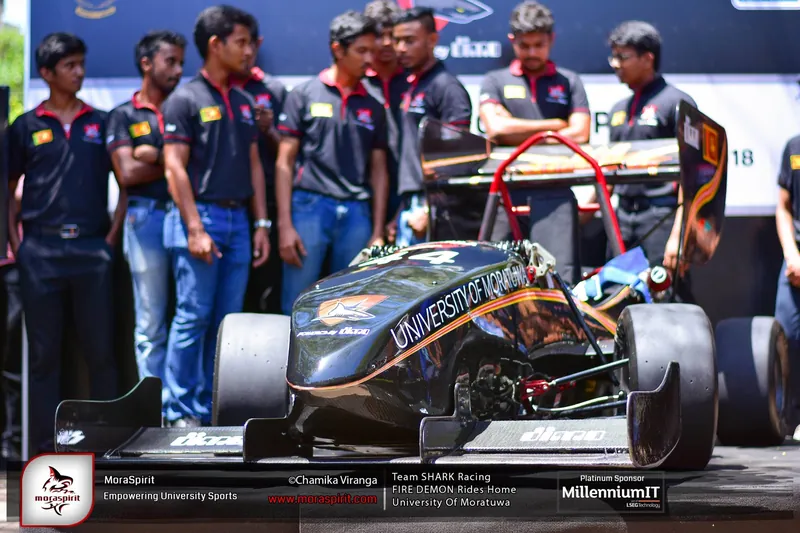
DI - Mora P2, Formula student car developed by Team SHARK officially unveiled at the University of Moratuwa on 29th of June 2018. Event was hosted by Department of Mechanical En...
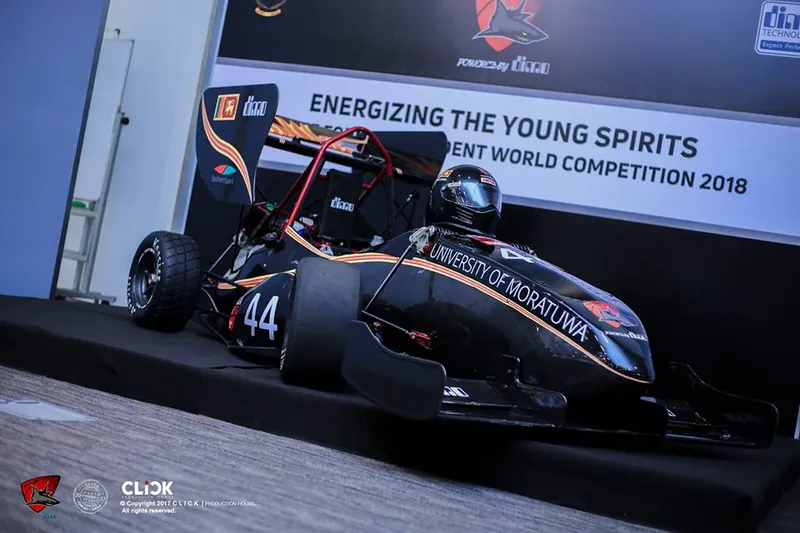
Formula Student (FS) is Europe’s most established educational motor-sport competition, run by the Institution of Mechanical Engineers (IMechE).
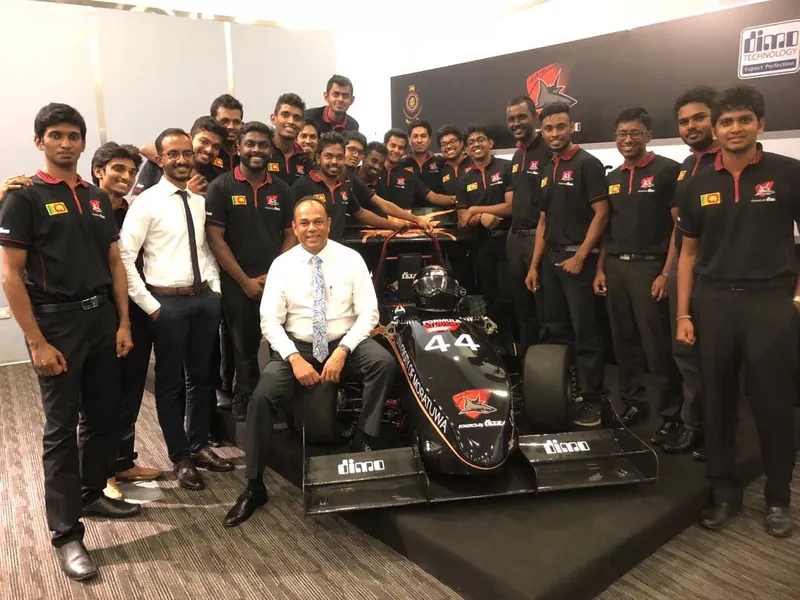
With the Highest level of technicality, expertise and the love for what they do, Team SHARK proudly unveiled the astounding Beast, DI-MORA P2 inspired by our very own “Giri Yaka...
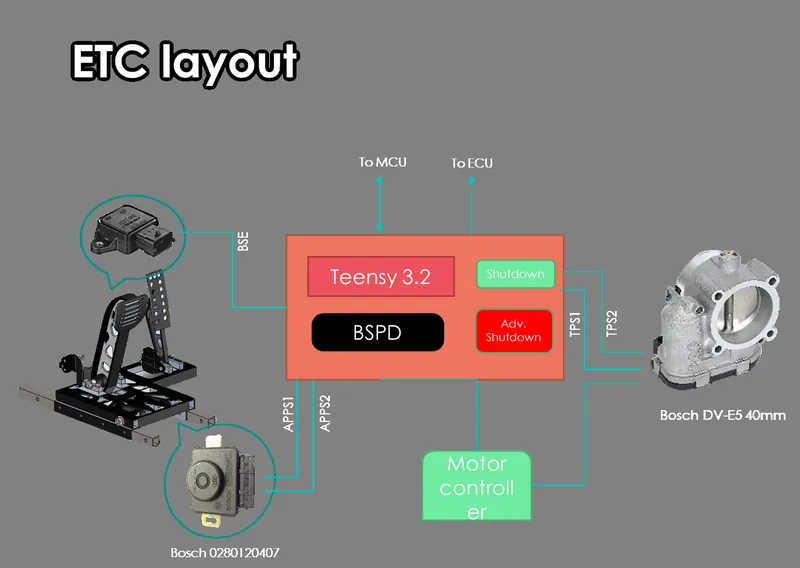
Clutch less shifting electronic throttle requires to provide fine throttle cuts and blips. After considering a custom throttle body design decision was made to purchase Bosch DV...
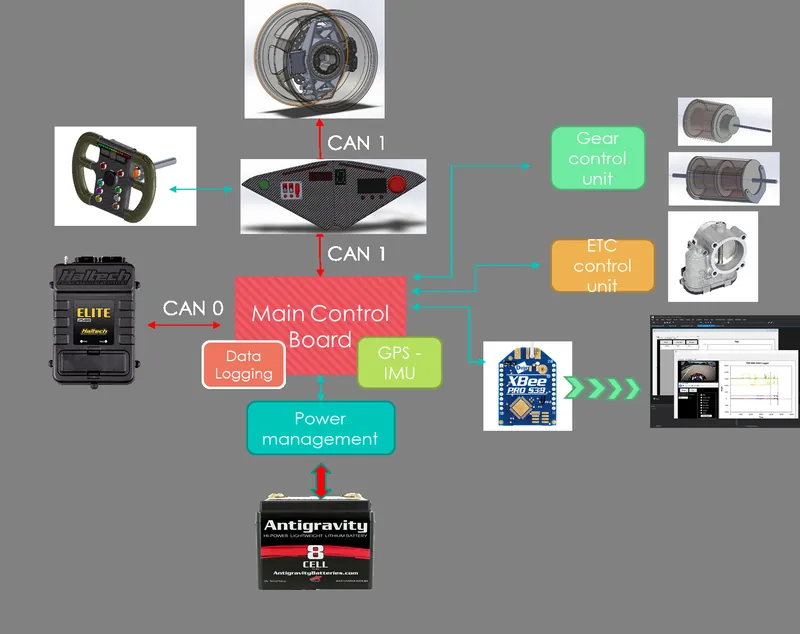
Lack of a custom electrical system and a Data acquisition system in the previous iterations of TSR cars made the designing team lean on results and data to verify their mathemat...
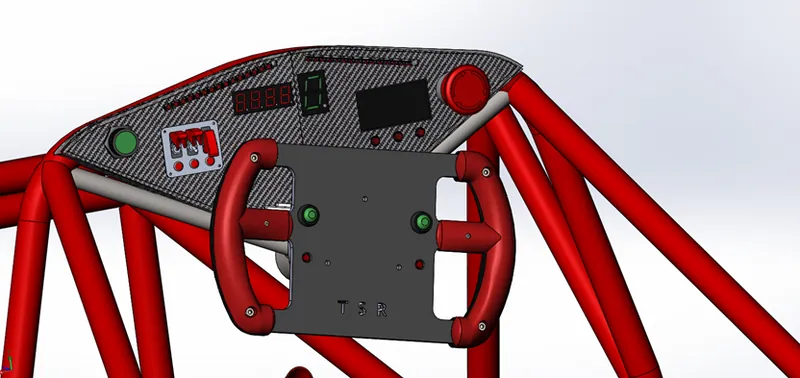
OEM race pack dashboards are not designed for open wheel racing. So it’s heavy, the display is not visible in the daylight and drivers struggle to notice vital information.
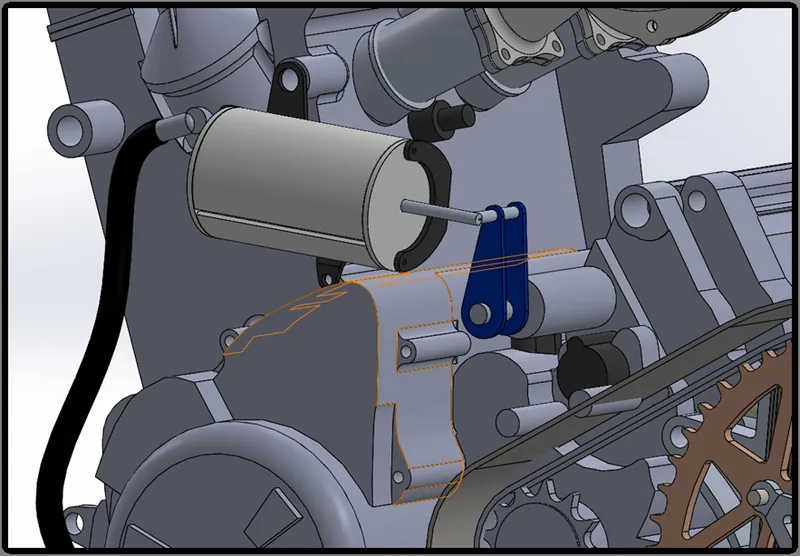
The Engine of the DI-MORA P2 (Yamaha MT07) has a sequential gear box.
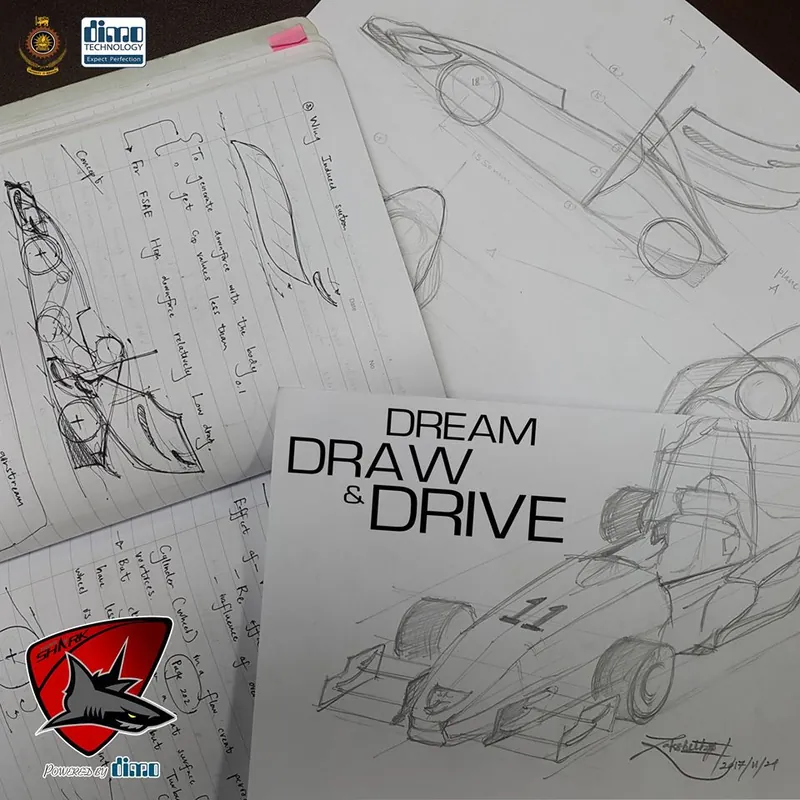
Team SHARK Racing with DIMO offered it's fans a chance to wind a exclusive karting session with the team by sending sketch designs of TSR car. Winners were selected and Karting ...
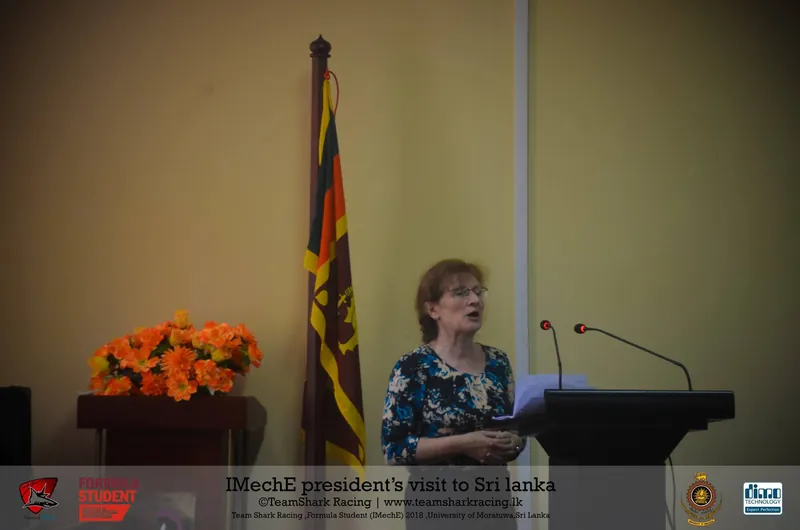
Opening a new chapter in Sri Lankan engineering history, president of Institute of Mechanical Engineers (IMechE), Mrs. Carolyn Griffiths visited University of Moratuwa on 17th o...
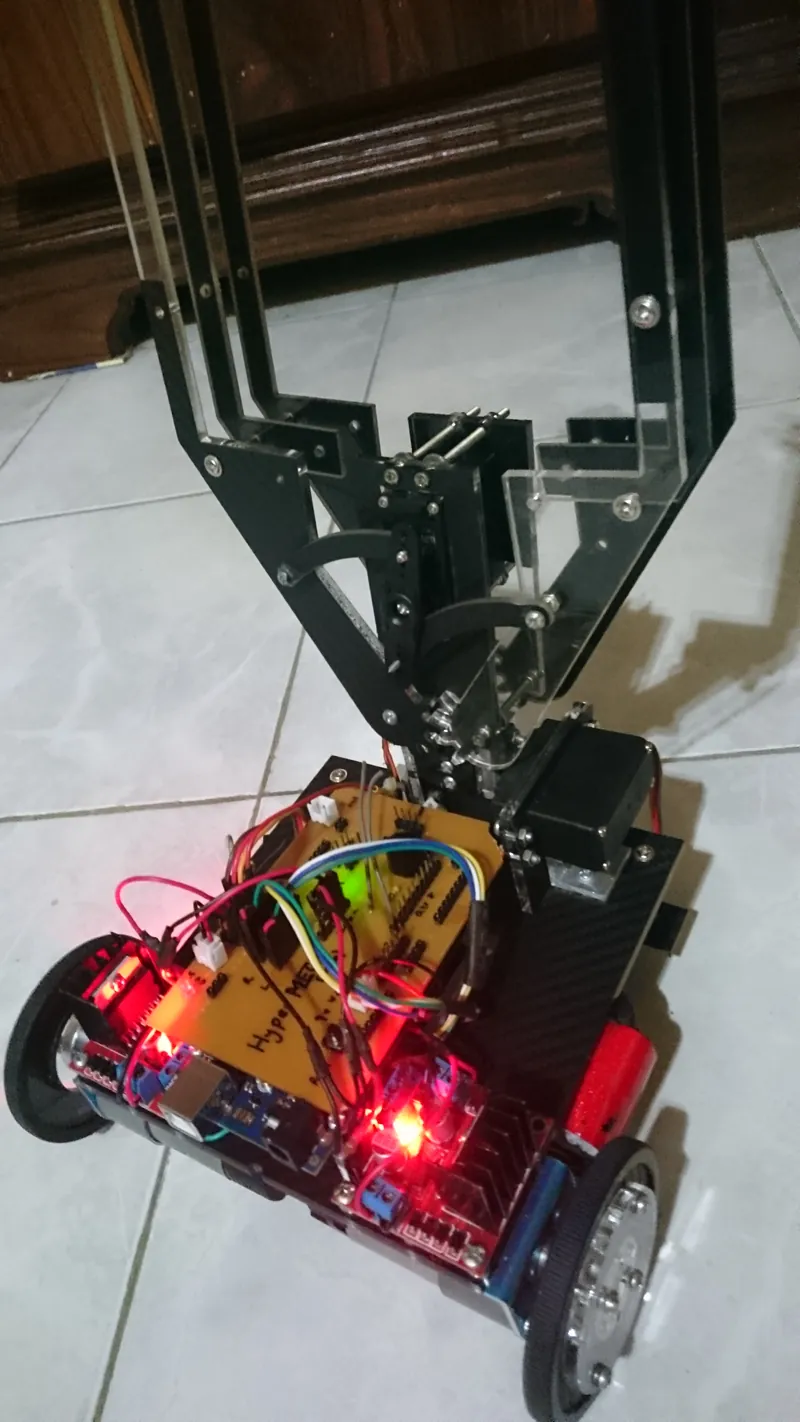
This Arduino based Line follower robot is developed to compete at the Sri Lankan Robotics Challenge 2017 competition held at University of Moratuwa.
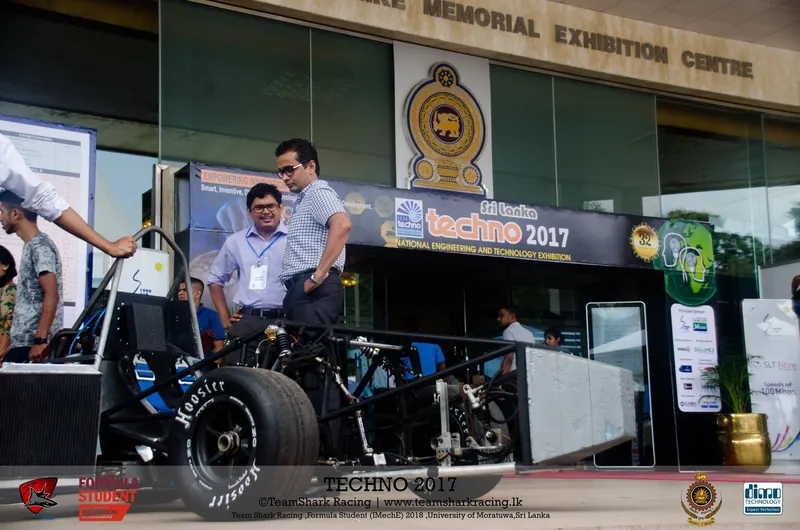
Team SHARK Racing from University of Moratuwa showcased their pride and joy in the form of two amazing Formula Student Racing cars at the Techno 2017, organised by IESL which wa...
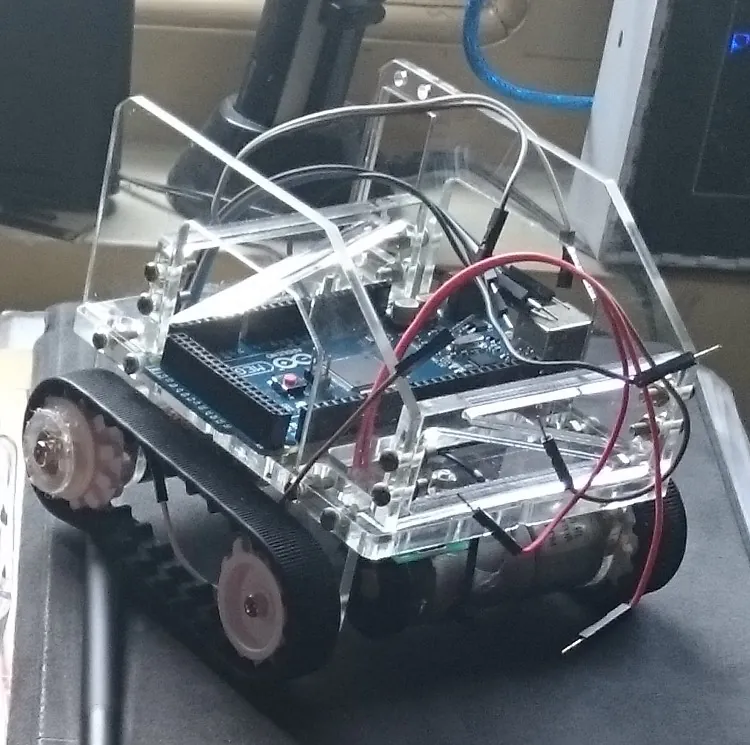
This is a Arduino based tracked robot designed to be as compact as possible. Fully perspex chassis makes it easy to assemble and Rugged.
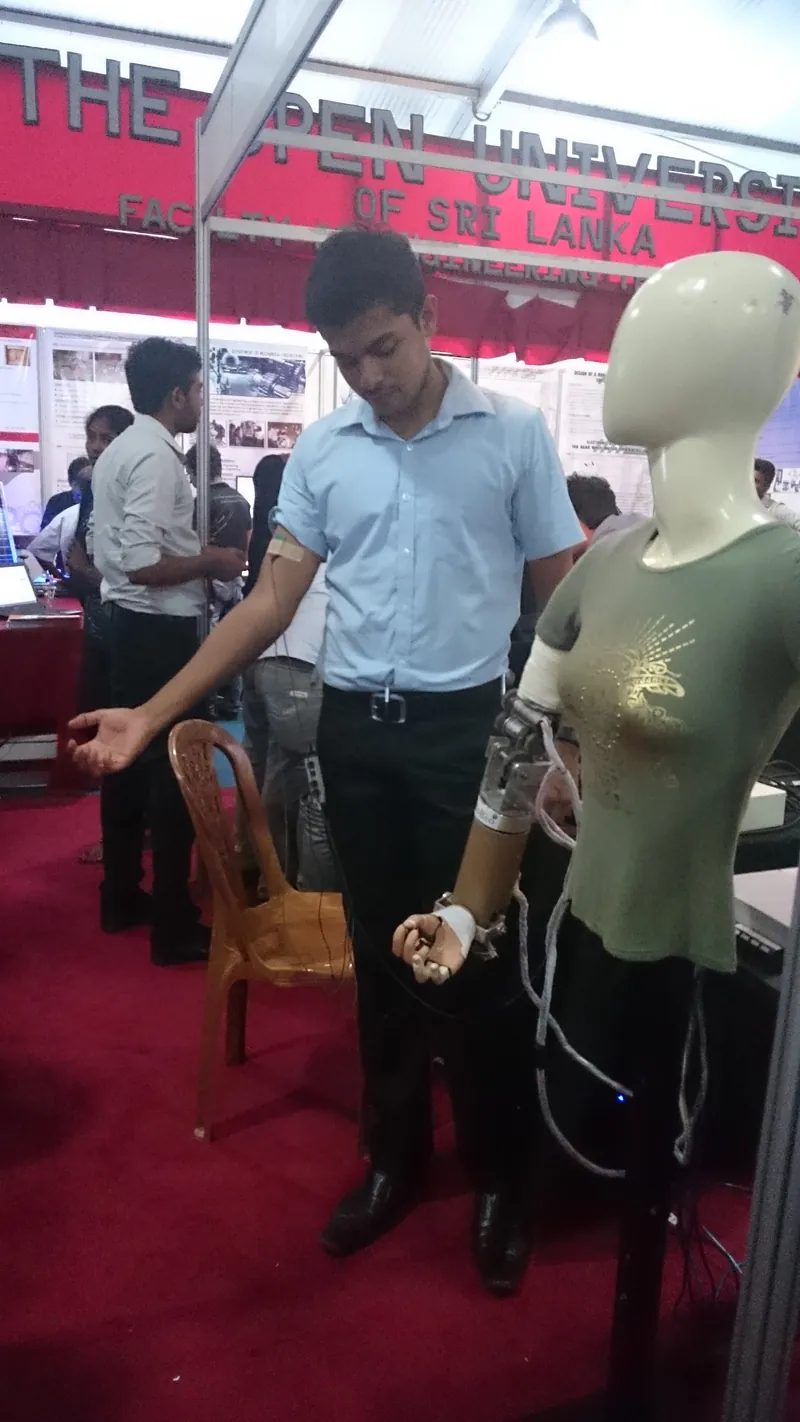
This prosthetic arm is designed for a amputee who lost the arm above elbow joint (Ulna).
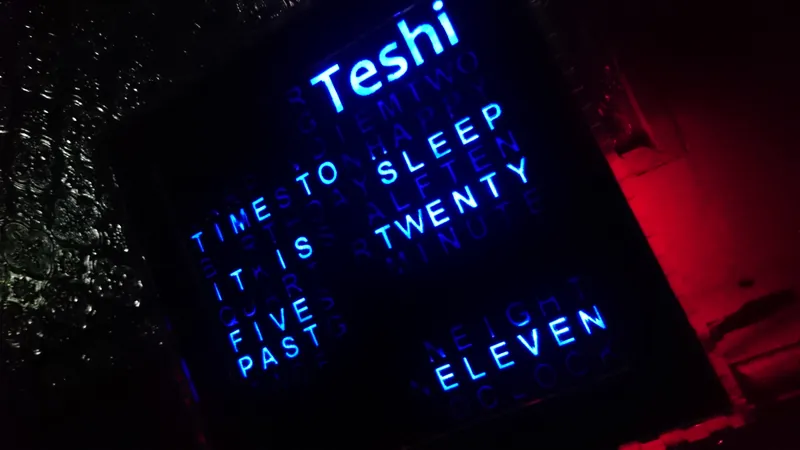
This build is a unique personalized gift that’s cool and reflects the character of the recipient.
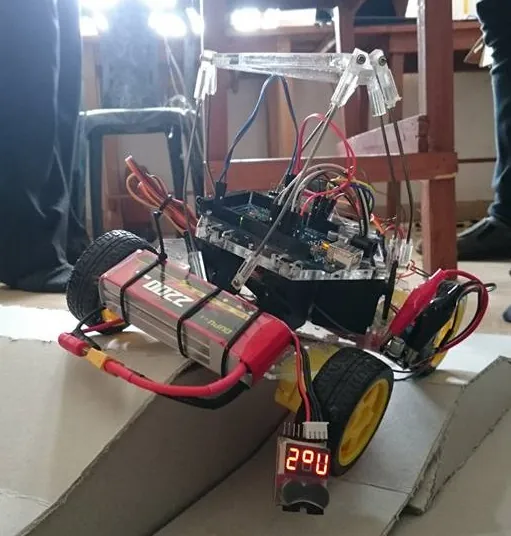
This 6 DOF mobile Stewart platform was developed as a course requirement of Semester 3 Mechatronics module. It has the capability to balance and stabilize in 6 DOFs and the Blue...
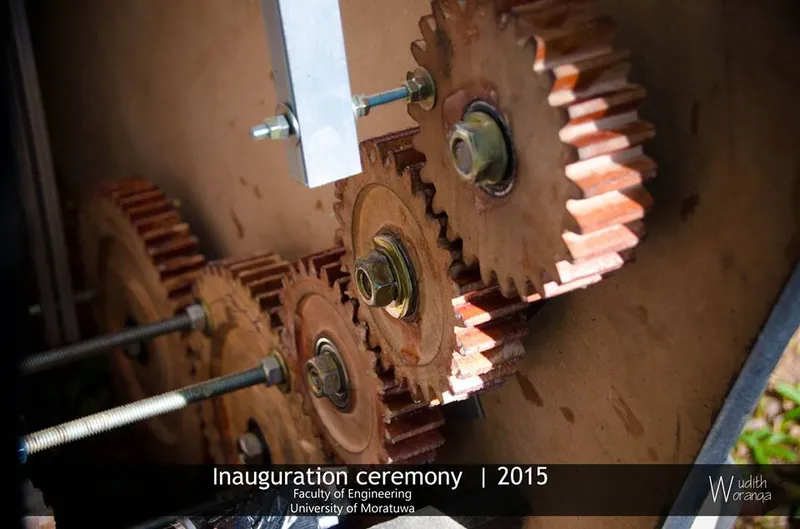
This is an animated mechanical real size human figure designed based on a gear mechanism. This was a Exhibit at the 2015 inauguration ceremony of University of Moratuwa.
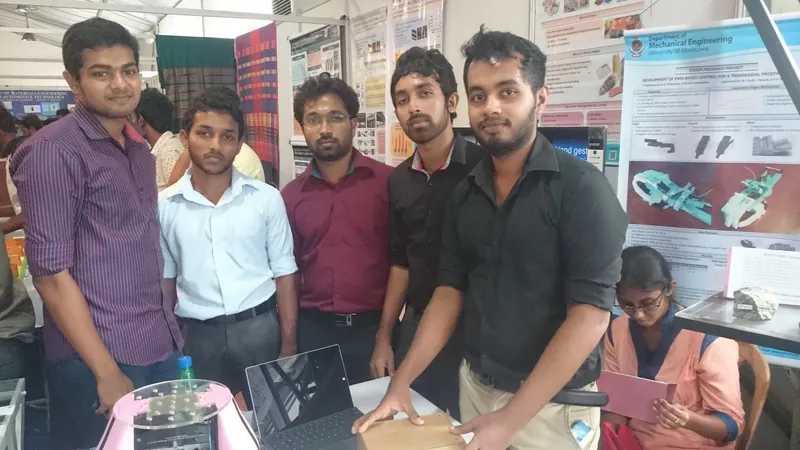
The EMG controlled feeder project won the Best Undergraduate project award at the TECHNO 2015 exhibition which was held form 9th to 11th October 2015.
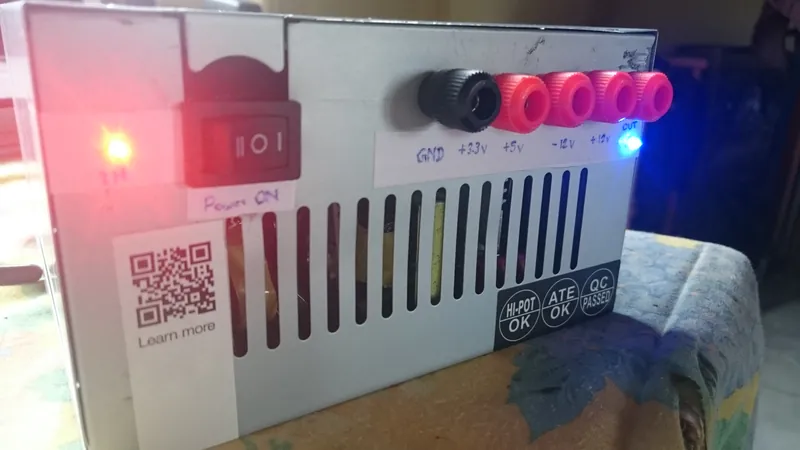
This bench power supply is made using an old PC ATX switching type power supply. 4 separate levels of voltages can be obtained.
2026
IEEE Robotics and Automation Letters (RA-L), vol. 11, no. 5, pp. 6114–6121
2026
IEEE International Conference on Robotics and Automation (ICRA), pp. 8558–8565
2026
International Conference on Unmanned Aircraft Systems (ICUAS), pp. 844–852
2026
International Conference on Unmanned Aircraft Systems (ICUAS), pp. 207–212
Flight tests, simulations and talks.